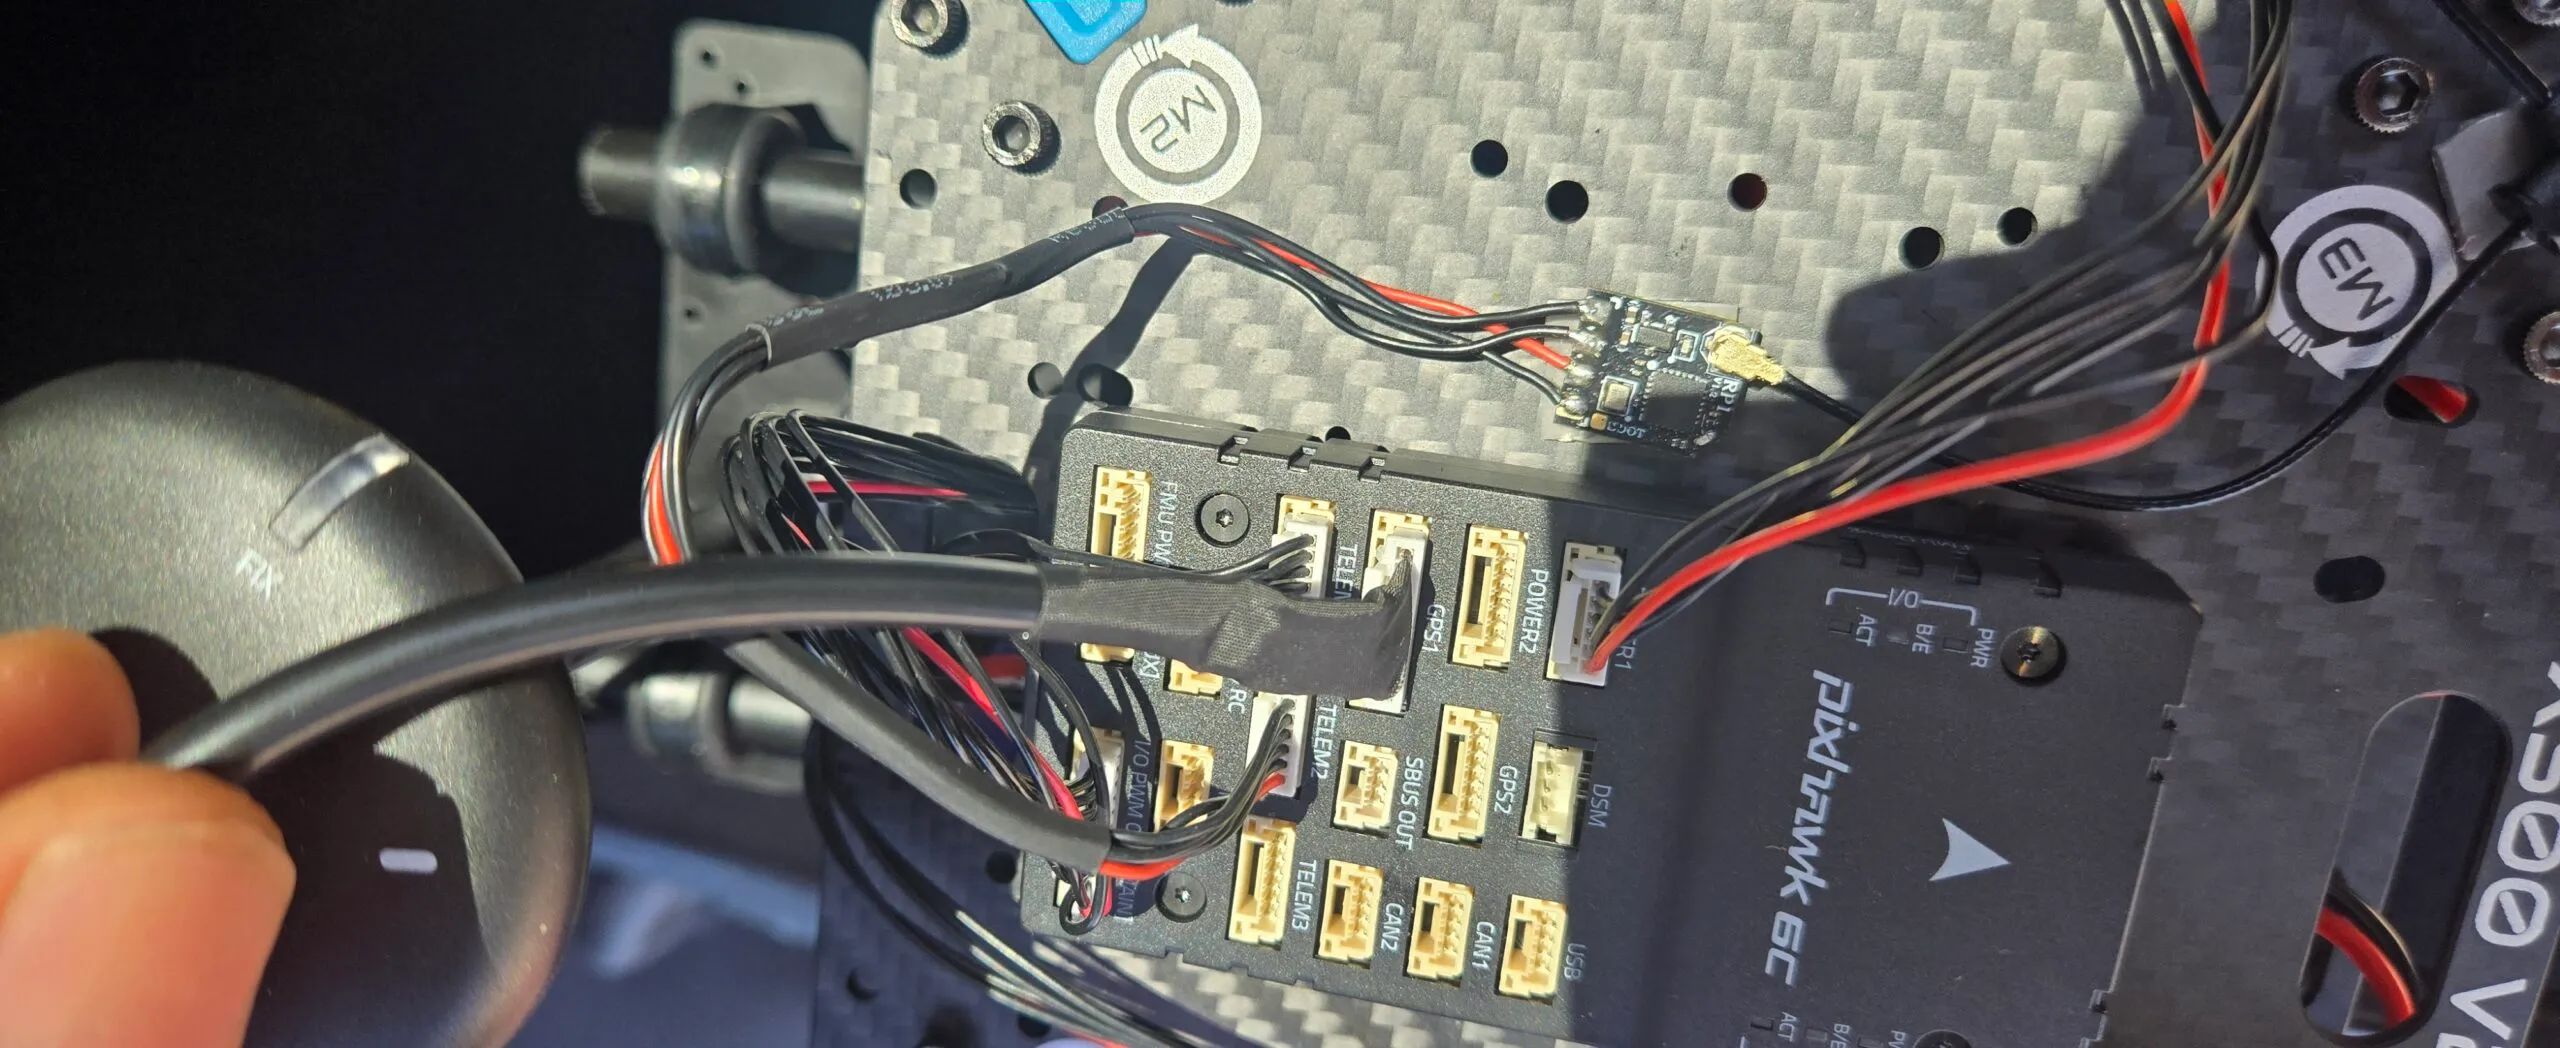
Autonomous object-tracking drone
A PX4 X500 quadcopter that detects and follows a target, running YOLO on a Raspberry Pi 4 with ROS 2 talking to a Pixhawk 6C.
Specs: Airframe build · PX4 setup · ROS 2 · YOLO detection · Flight validation
the magazine of questionable gear
Issue 05September 2026$0.00 · free with GitHub
Real builds, real wiring, real crashes. 5 features and counting. Every back issue
Machines, drones, drivers and software he actually built. Zero sponsored. All the gear
A PX4 X500 quadcopter that detects and follows a target, running YOLO on a Raspberry Pi 4 with ROS 2 talking to a Pixhawk 6C.
Specs: Airframe build · PX4 setup · ROS 2 · YOLO detection · Flight validation
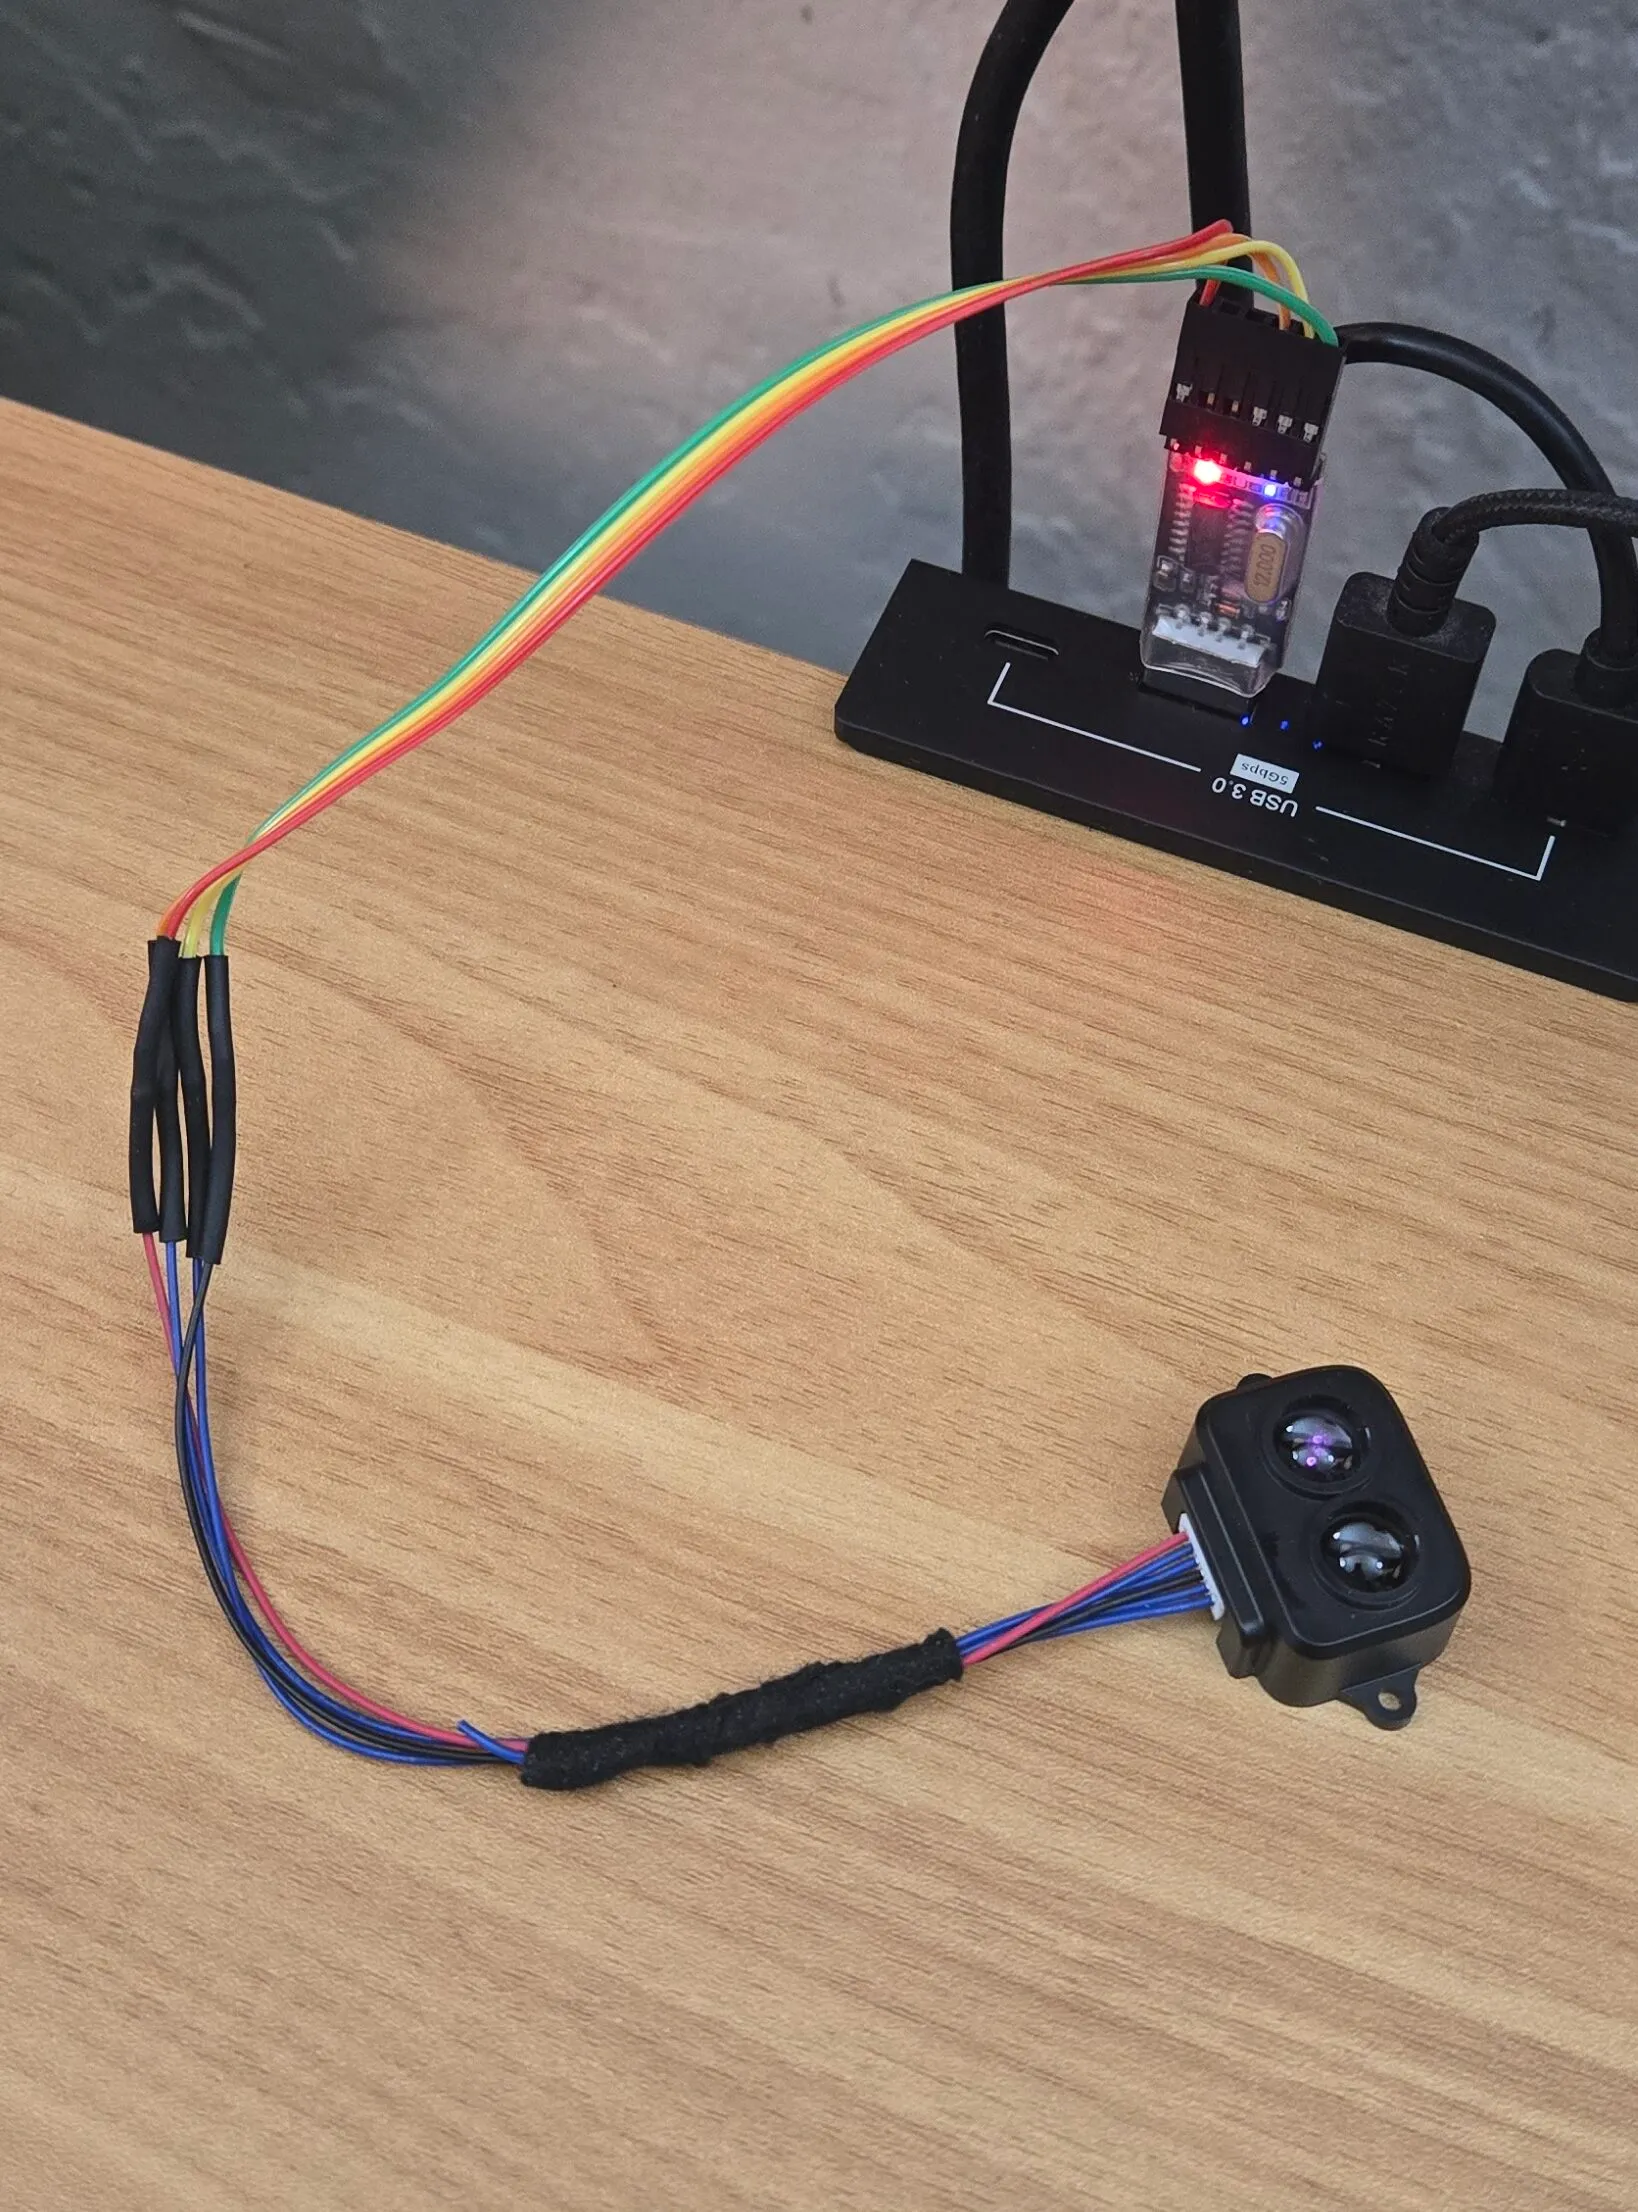
Pure-Python ROS 2 drivers for two low-cost LiDARs: the Benewake TF-Luna (single point, UART) and the YDLIDAR X2 (360° scan).
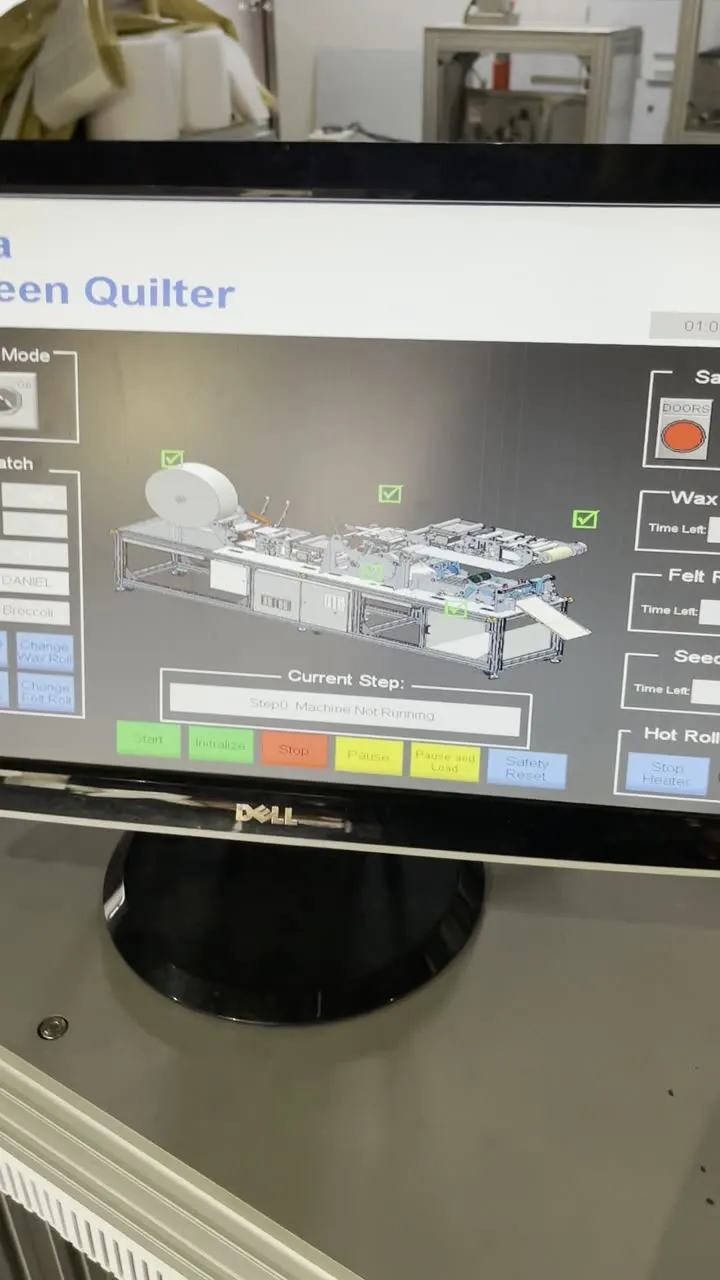
I helped design and build a seed quilting machine by developing the control system and programming the PLC and HMI. I also handled wiring, validated all mechanisms, and brought the entire machine together into a fully functional system.
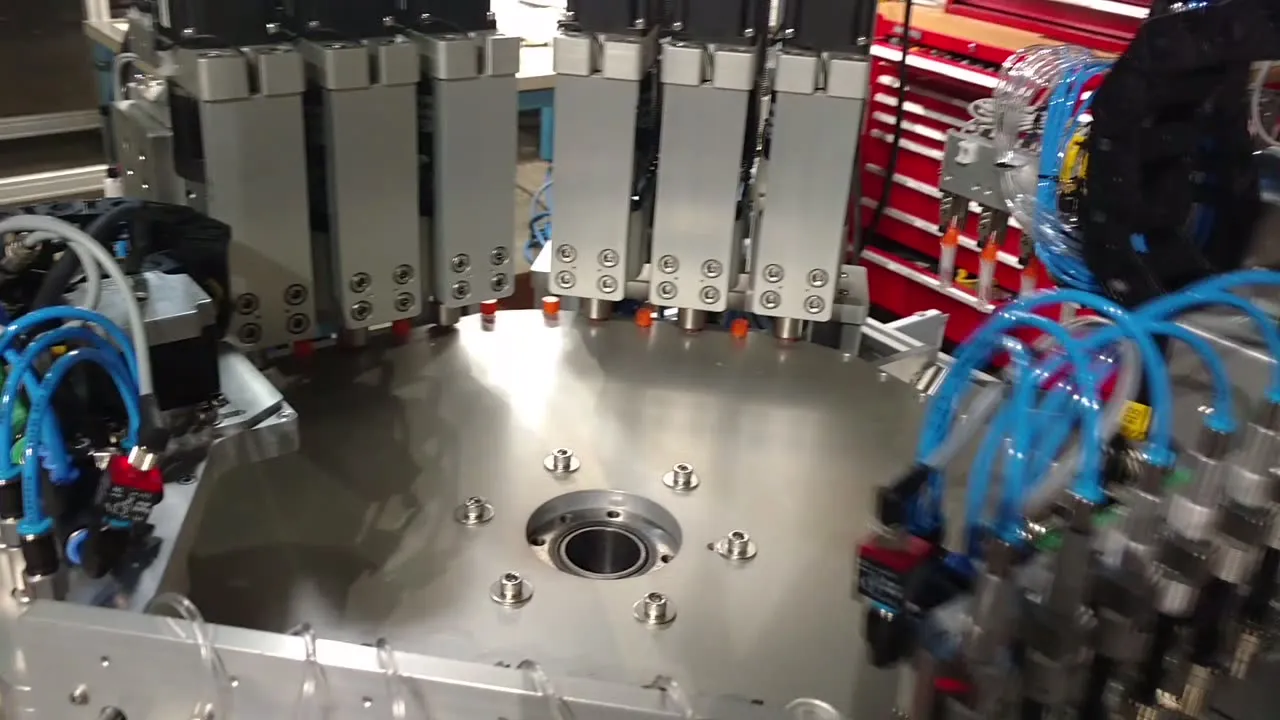
I contributed to the development of a COVID-19 vial filling machine by programming the PLC and HMI, and validating valves and actuators to ensure reliable performance. I also handled system wiring and helped integrate all components into a fully functional, production-ready system.
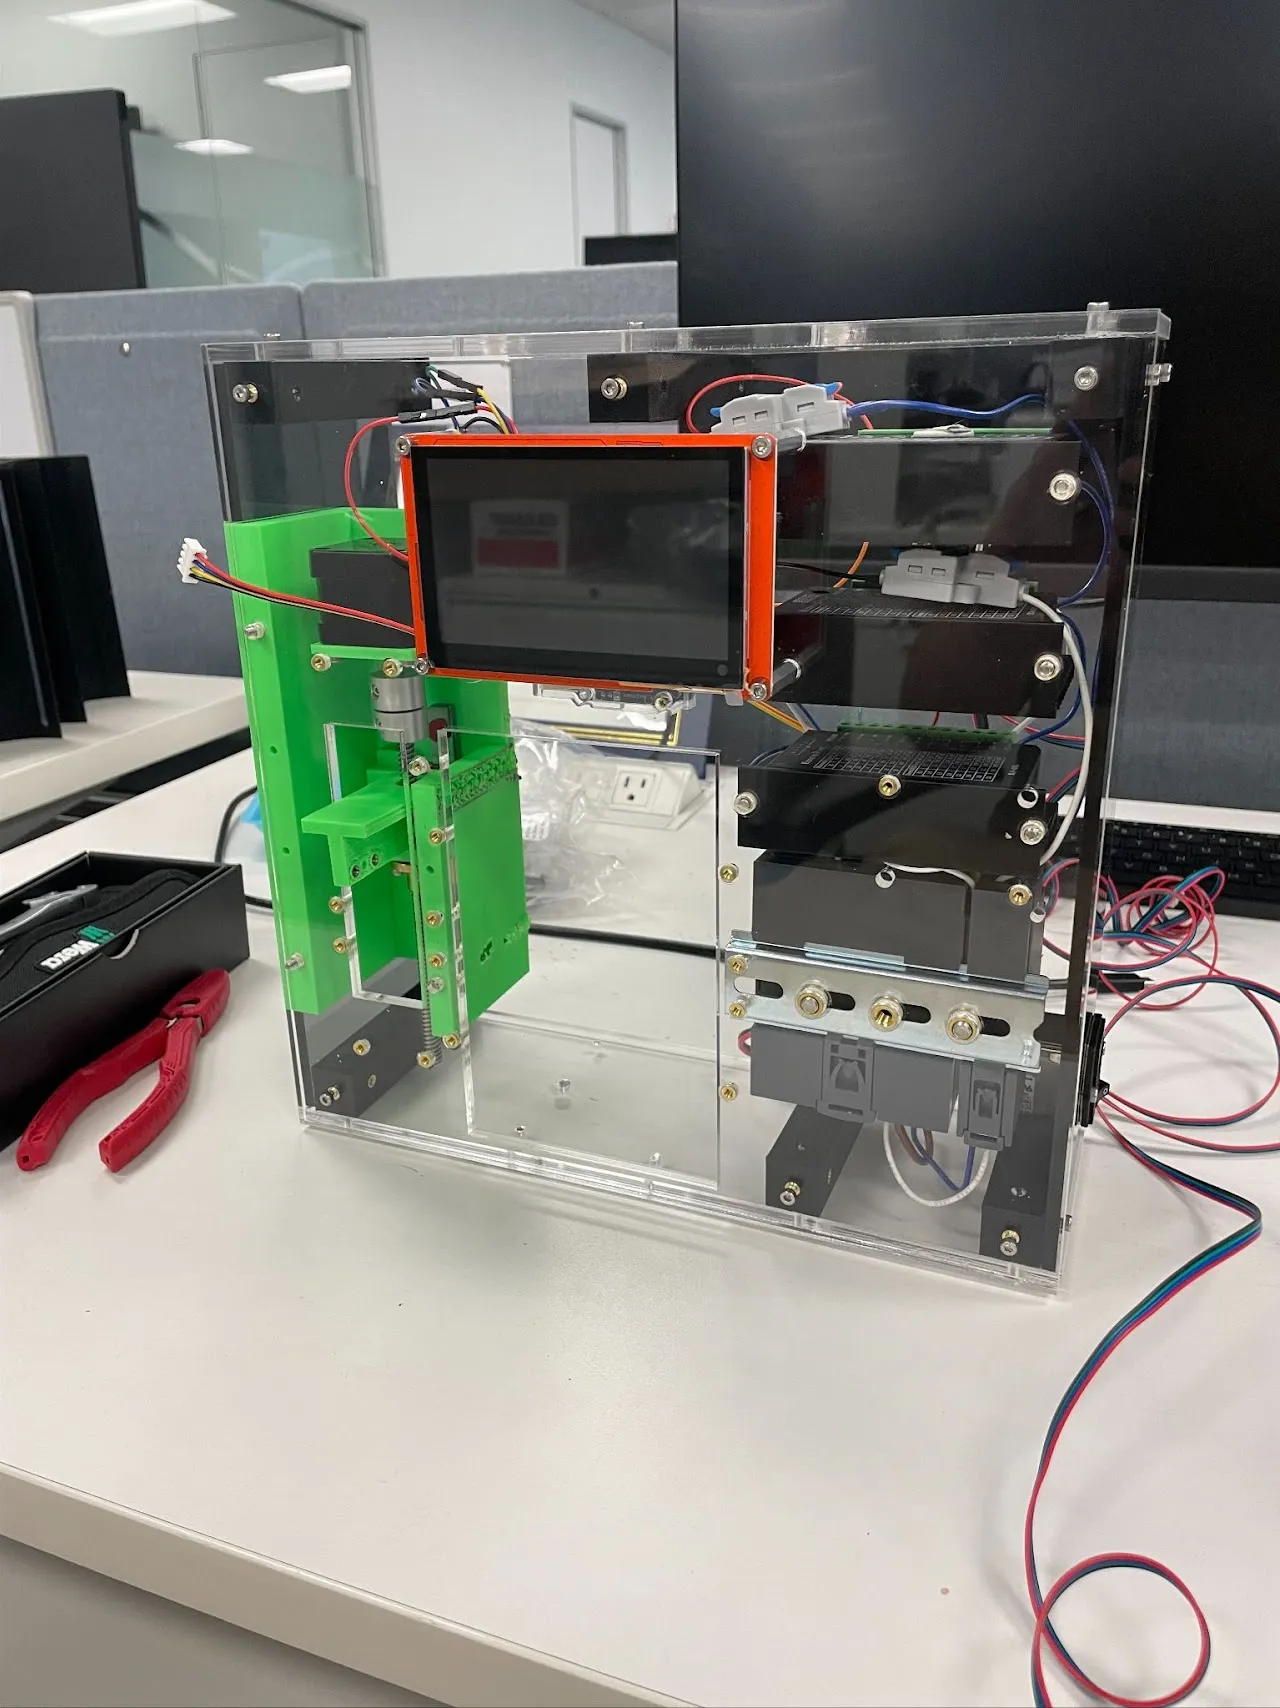
I designed and built an automated tube cutter by developing the control system, programming the PLC and HMI, and integrating stepper-driven motion for precise cutting. I also handled wiring, validated system performance, and brought the machine together into a reliable, fully functional system.
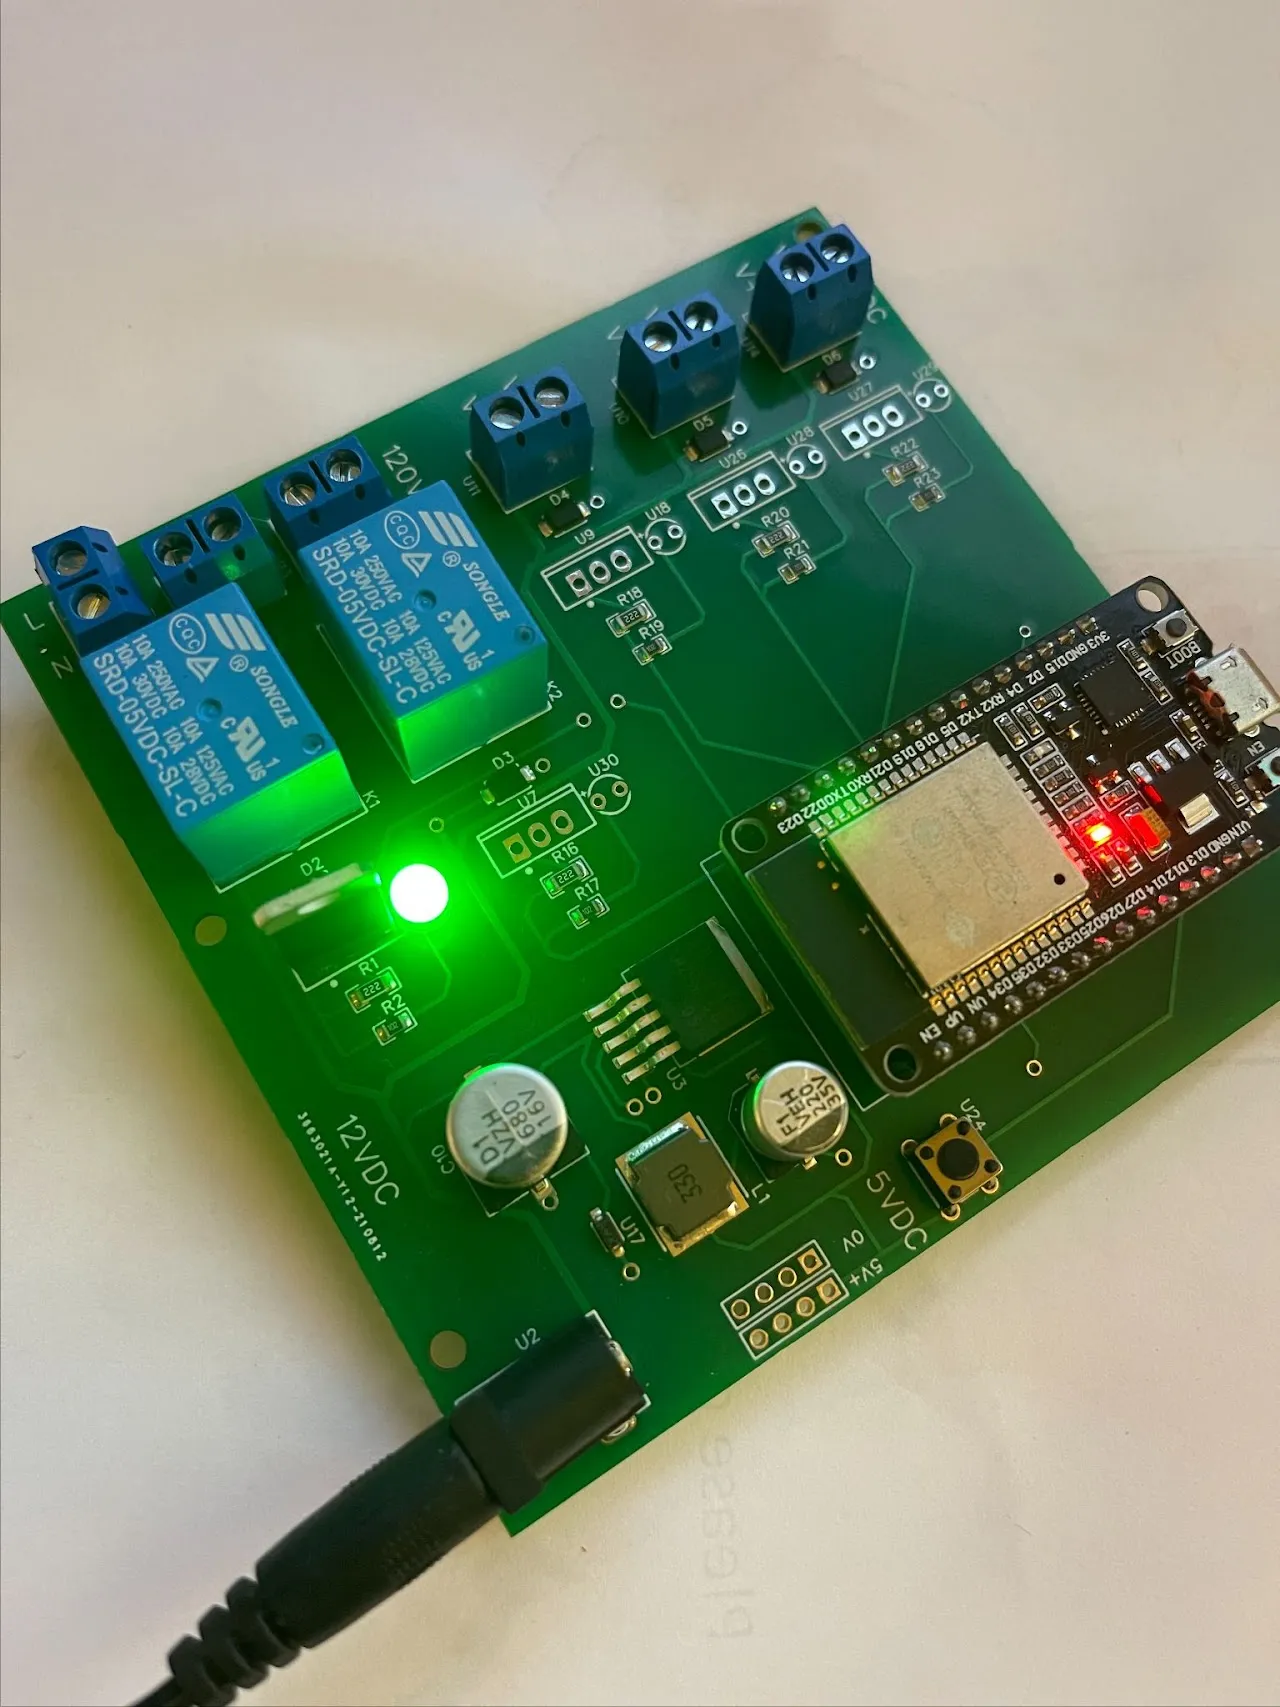
I designed a custom hydroponics control PCB integrating an ESP32, taking it from schematic to layout and manufacturing through JLCPCB. The board functioned as intended, successfully validating the design and hardware integration.
| Roche Diagnostics | Senior Mechanical Design Engineer |
|---|---|
| Production Robotics | Automation Engineer |
| George M. Martin | Controls Engineer |